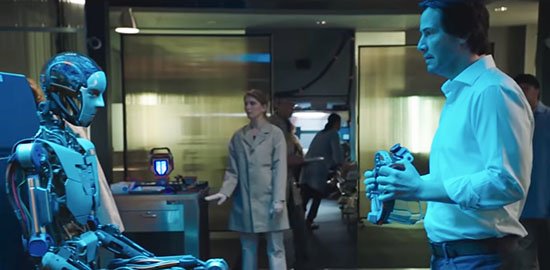
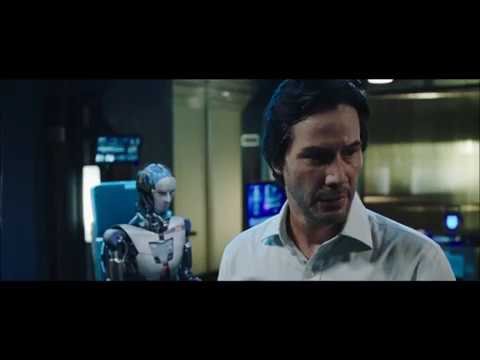
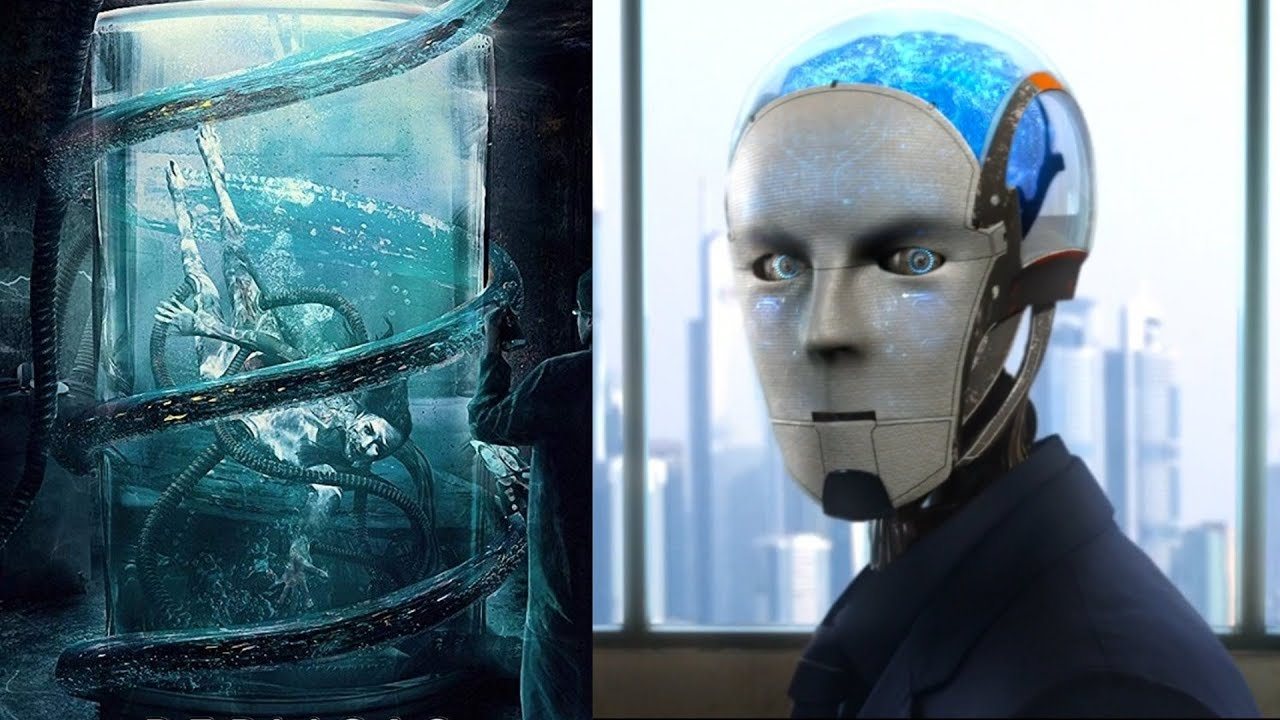
Rig creation for the main robot. Adaptation of Mocap, suspension system, cable systems, and created tools to generate many parts of the rig.